I'm Ayberk
I build robots
Welcome
I'm Ayberk. I build robots.
based in Tokyo, Japan.
I design and build robots, combining mechanical design, embedded systems, control, and user interaction.
Let's meetAbout Me
I'm Ayberk
I'm currently pursuing my PhD at the Mechanical Systems Design Laboratory, Institute of Science Tokyo. My research focuses on human biomechanics, robotic neck assistance, and the design and evaluation of assistive mechanisms.
My recent work includes the design and task-space evaluation of a 3-URS parallel human neck assistance robot and a cross-validated regression model for cervical spine pose estimation. I combine mechanical modelling, motion capture, and electromyography (EMG) to study human movement and inform assistive robot design.
Previously, I founded Mekadermis (2018–2024), an Istanbul-based startup focused on robotics and automation. I led development across mechanical design, embedded electronics, firmware, and control systems, delivering customized solutions for industrial clients.
- Name:Ayberk SADIC
- Contact:LinkedIn
- Based in:Tokyo, Japan
Skills
Robotics Specialization
Robot kinematics and dynamics, sensor integration, and system integration. Python, ROS1/2, embedded Linux, and OpenCV.
Mechanical Design
Mechanism and structural design, CAD/CAE, actuator selection, prototyping, and testing. Autodesk Fusion/Inventor and SolidWorks.
Control Systems Design
Controller design and implementation for robotic systems, electric motors, and pneumatic actuators. MATLAB and Simulink.
Biomechanics and Data Analysis
Musculoskeletal modelling, motion capture, EMG, and statistical analysis for assistive robotics. AnyBody Modeling System and Python.
Embedded Software Development
Firmware and embedded Linux integration. C/C++, STM32, ESP32, ARM Cortex-M, FreeRTOS, and I²C/SPI/UART/CAN communication.
Electronics Design
Circuit schematics, multilayer PCBs, actuator drivers, and sensor interfaces. Hardware bring-up, oscilloscope and logic-analyzer debugging, and validation.
Resume
My Education
Apr 2024 – Mar 2027 (Expected)
Mechanical Engineering, PhD Candidate
Institute of Science Tokyo (東京科学大学) - Tokyo, Japan
Member of Takeda-Sugahara Mechanical Systems Design Laboratory. Research on human biomechanics and assistive robotic exoskeletons.
Sep 2019 – Mar 2023
Business Administration, MBA
Université Galatasaray - Istanbul, Turkey
Research on financial anxiety, financial literacy, and mental accounting processes.
Sep 2011 – Jun 2016
Mechanical Engineering, BSc.
Middle East Technical University - Ankara, Turkey
Thesis title: "Development of human trunk exoskeleton using pneumatic artificial muscles".
My Experience
Aug 2025 – Present
Robotics Engineer
Yukai Engineering - Tokyo, Japan
Design and development of robotic products, embedded systems, and conversational AI platforms. Hardware integration, testing, and validation.
Jan 2018 – Feb 2024
Founder and Systems Architect
Mekadermis - Istanbul, Turkey
Istanbul-based robotics and automation company.
Aug 2016 – Jan 2018
Teaching & Research Assistant
Koç University - Istanbul, Turkey
Conducted research on robotics and human–machine interaction. Taught in control systems design and bachelor’s thesis courses.
Selected Publications
Design and Task Space Evaluation of 3-URS Parallel Human Neck Assistance Robot
Sadic, A., & Sugahara, Y. (2026). ROMANSY 26 – Robot Design, Dynamics and Control. Springer, pp. 44–54. Published September 14, 2026.
Read the conference articleA K-Fold Cross-Validated Regression Model for Cervical Spine Pose Estimation Trained on X-Ray Images
Sadic, A., & Sugahara, Y. (2025). IEEE International Conference on Robotics and Biomimetics (ROBIO), pp. 49–54.
Read the conference articleExploration strategies for tactile graphics displayed by electrovibration on a touchscreen
Sadia, B., Sadic, A., Ayyildiz, M., & Basdogan, C. (2022). International Journal of Human-Computer Studies, 160, 102760.
Read the journal articleSelected Projects
Neck Assistance Robotics
Doctoral research · Institute of Science Tokyo
My doctoral research explores robotic neck assistance and cervical spine modelling through related studies in mechanism design, pose prediction, and biomechanical simulation.
Robot Design
Design and task-space evaluation of a 3-URS parallel robot for human neck assistance. My work covers the mechanism’s design, kinematics, and evaluation of its task space. View the RoManSy 2026 publication.
Biomechanical modelling
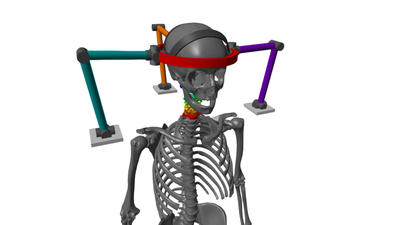
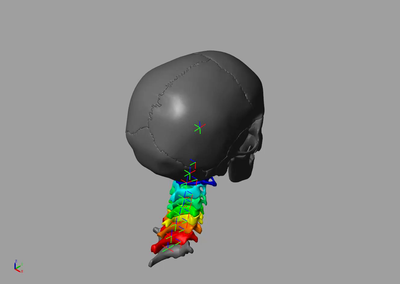
Human head-neck motion simulation
This biomechanical model simulates human head and neck motion. It was initially introduced in our RoManSy 2026 paper on the design and task-space evaluation of a 3-URS parallel human neck assistance robot. View the RoManSy 2026 publication.
Cervical vertebrae pose estimation
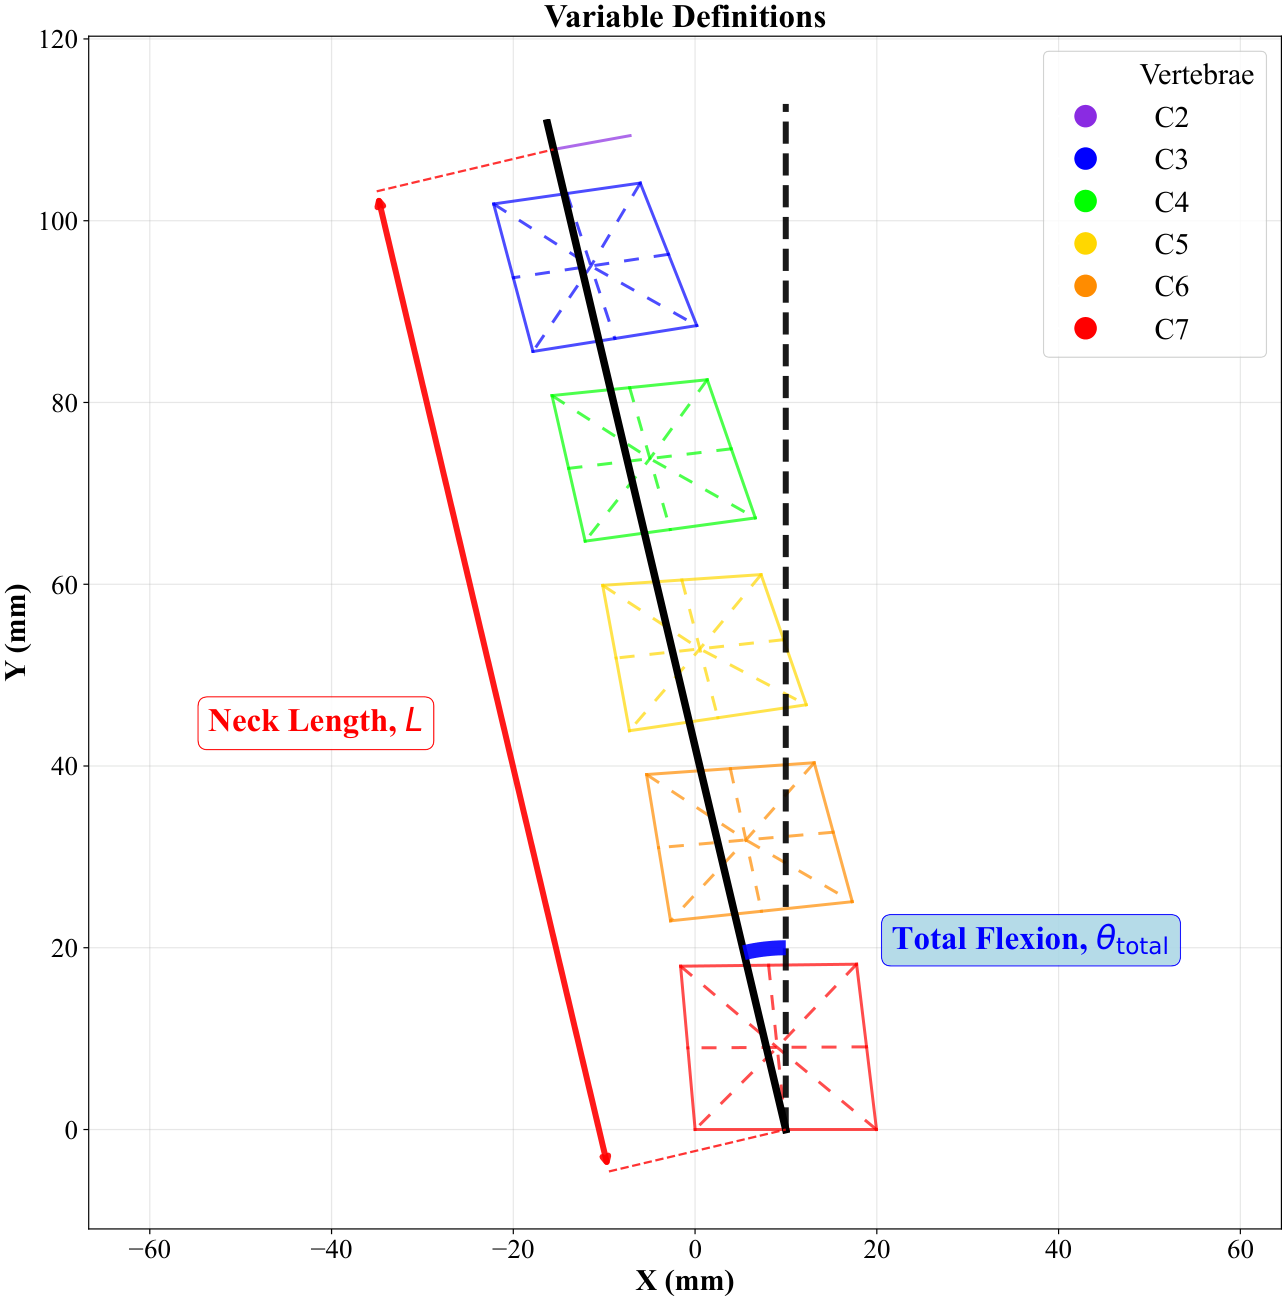
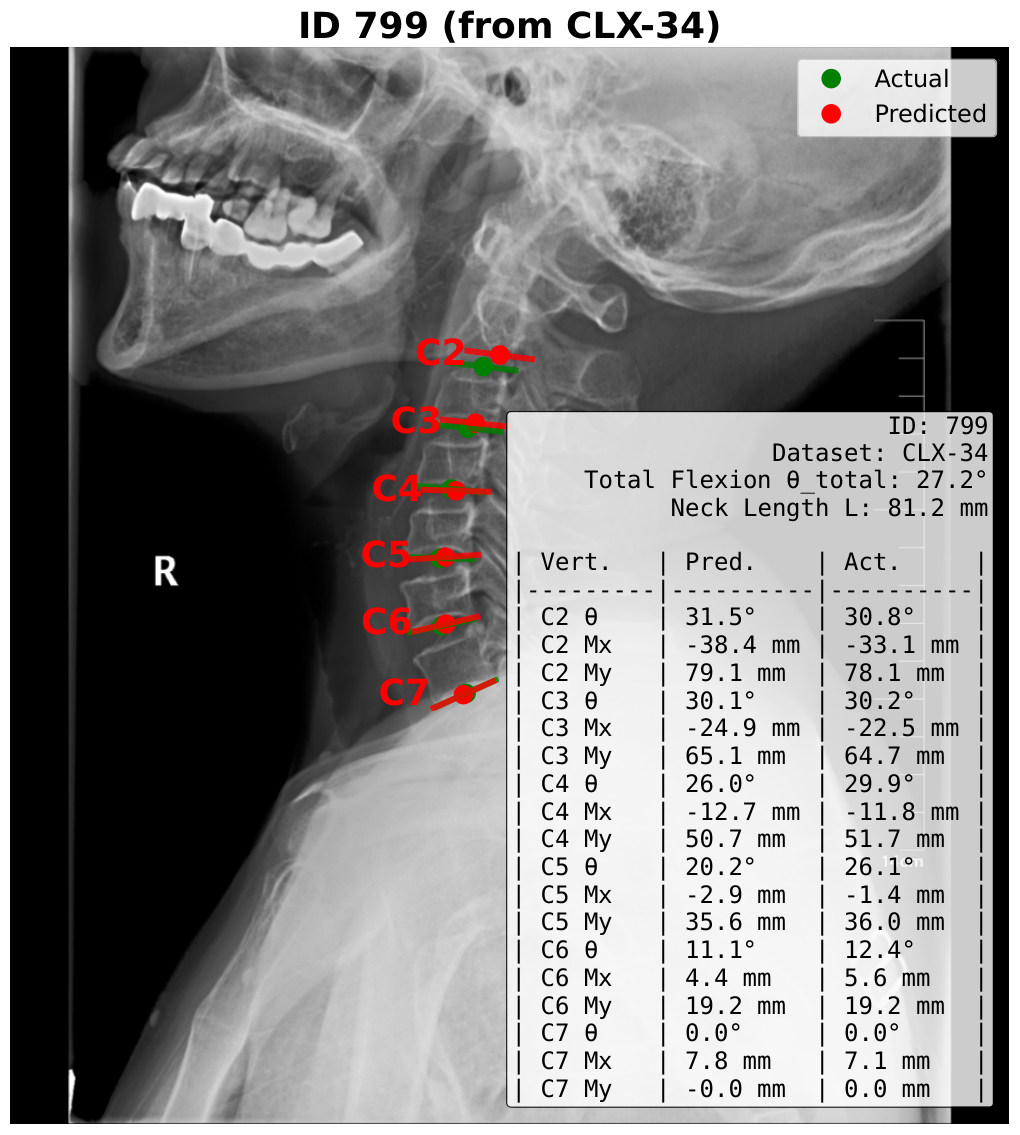
We developed a regression model that predicts cervical vertebrae pose from neck length and total neck flexion angle. Trained on X-ray images and evaluated using K-fold cross-validation, the model estimates the positions and orientations of the cervical vertebrae. View the ROBIO 2025 publication.